
161
@dataclass
class AgentConfig:
   horizon: int = 6
   replan_on_target_move: bool = True
   replan_on_obstacle_change: bool = True
   max_steps: int = 120
   think_latency: float = 0.02
   act_latency: float = 0.01
   risk_gate: float = 0.85
   alt_search_depth: int = 2


@dataclass
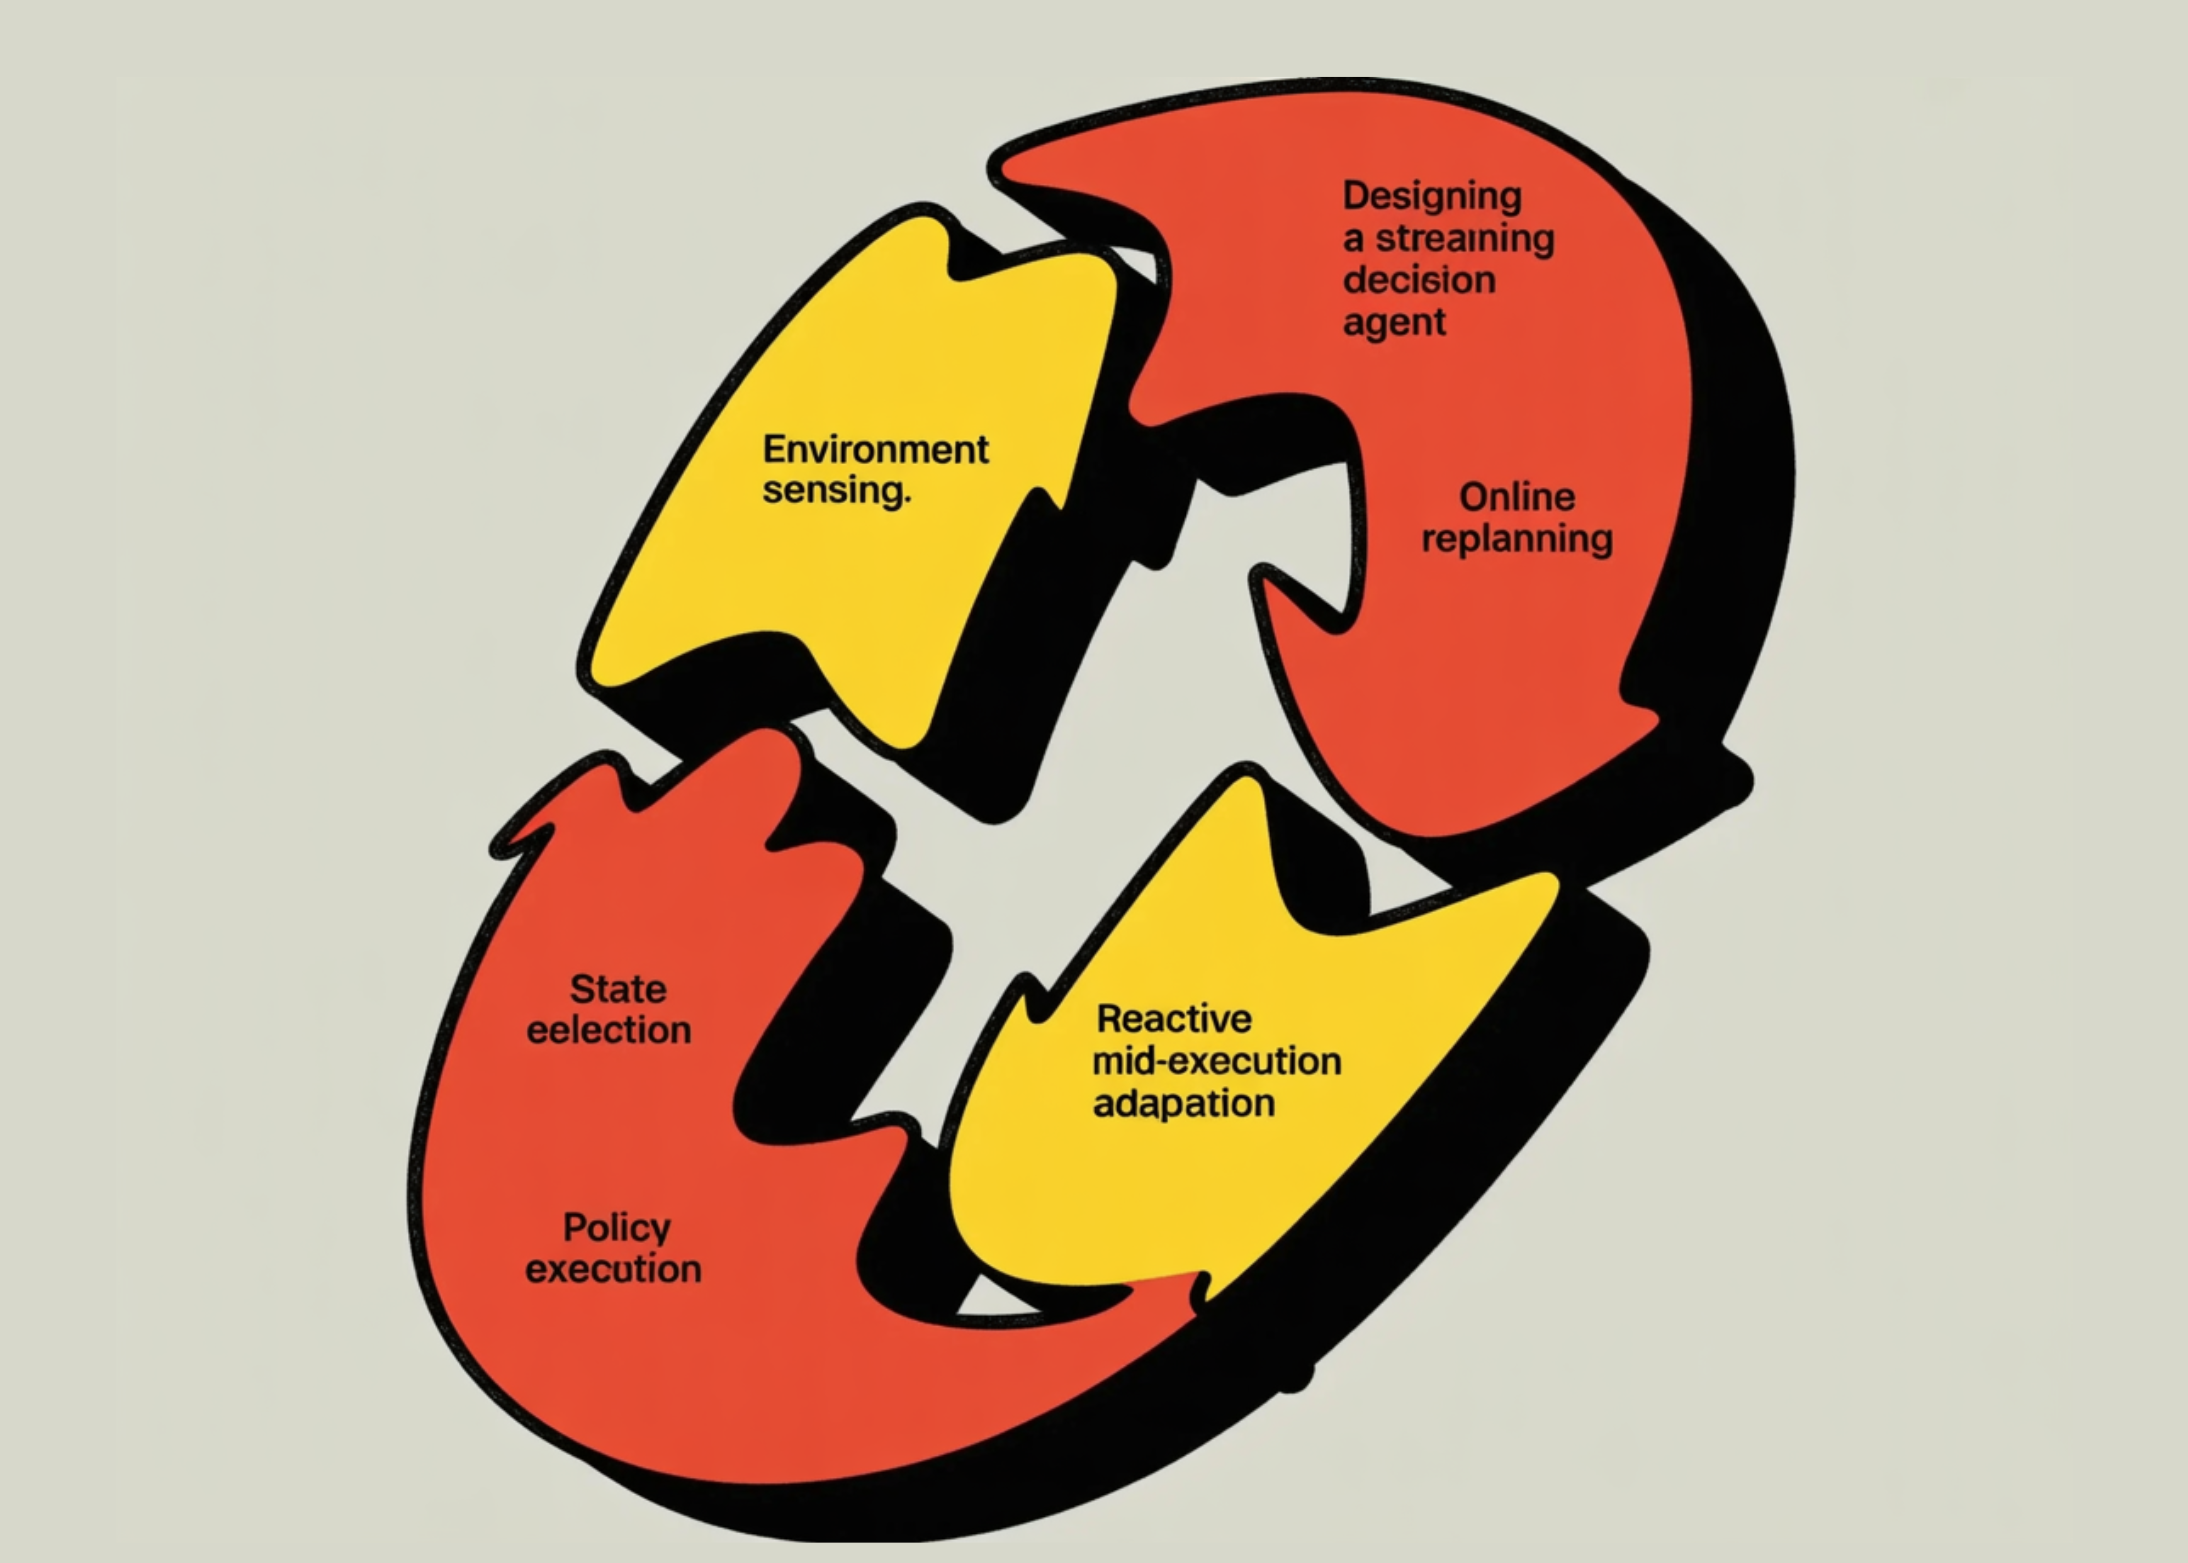
class StreamingDecisionAgent:
   cfg: AgentConfig
   world: DynamicGridWorld
   start_time: float = discipline(init=False, default_factory=time.time)
   step_id: int = discipline(init=False, default=0)
   current_plan: Listing[Coord] = discipline(init=False, default_factory=checklist)
   current_actions: Listing[str] = discipline(init=False, default_factory=checklist)
   last_snapshot: Dict[str, Any] = discipline(init=False, default_factory=dict)
   stats: Dict[str, Any] = discipline(init=False, default_factory=lambda: defaultdict(int))


   def _now(self) -> float:
       return time.time() - self.start_time


   def _emit(self, sort: str, msg: str, information: Elective[Dict[str, Any]] = None) -> StreamEvent:
       return StreamEvent(t=self._now(), sort=sort, step=self.step_id, msg=msg, information=information or {})


   def _need_replan(self, obs: Dict[str, Any]) -> bool:
       ch = obs["changes"]
       if obs["done"]:
           return False
       if not self.current_plan or len(self.current_plan) <= 1:
           return True
       if self.cfg.replan_on_target_move and ch.get("target_moved"):
           return True
       if self.cfg.replan_on_obstacle_change and (ch.get("obstacles_added") or ch.get("obstacles_cleared")):
           return True
       if len(self.current_plan) > 1 and self.current_plan[1] in self.world.obstacles:
           return True
       return False


   def _plan(self) -> PlanResult:
       time.sleep(self.cfg.think_latency)
       self.stats["replans"] += 1
       return astar(self.world, self.world.agent, self.world.goal)


   def _choose_action(self, planned_action: str) -> Tuple[str, str]:
       ax, ay = self.world.agent
       action_to_delta = {"R": (1,0), "L": (-1,0), "D": (0,1), "U": (0,-1), "S": (0,0)}
       dx, dy = action_to_delta[planned_action]
       nxt = (ax+dx, ay+dy)
       if not self.world.in_bounds(nxt) or not self.world.satisfactory(nxt):
           self.stats["overrides"] += 1
           return "S", "planned_move_invalid -> wait."
       r = action_risk(self.world, nxt)
       if r > self.cfg.risk_gate:
           candidates = ["U","D","L","R","S"]
           greatest = (planned_action, float("inf"), "keep_plan")
           for a in candidates:
               dx, dy = action_to_delta[a]
               p = (ax+dx, ay+dy)
               if not self.world.in_bounds(p) or not self.world.satisfactory(p):
                   proceed
               rating = action_risk(self.world, p) + 0.05 * self.world.manhattan(p, self.world.goal)
               if rating < greatest[1]:
                   greatest = (a, rating, "risk_avoidance_override")
           if greatest[0] != planned_action:
               self.stats["overrides"] += 1
               return greatest[0], greatest[2]
       return planned_action, "follow_plan"


   def run(self) -> Generator[StreamEvent, None, None]:
       yield self._emit("observe", "Initialize: studying preliminary state.", {"agent": self.world.agent, "goal": self.world.goal})
       yield self._emit("world", "Preliminary world snapshot.", {"grid": self.world.render()})
       for self.step_id in vary(1, self.cfg.max_steps + 1):
           if self.step_id == 1 or self._need_replan(self.last_snapshot):
               pr = self._plan()
               self.current_plan = pr.path
               self.current_actions = path_to_actions(pr.path)
               if pr.cause != "found_path":
                   yield self._emit("plan", "Planner couldn't discover a path inside funds; switching to reactive exploration.", {"cause": pr.cause, "expanded": pr.expanded})
                   self.current_actions = []
               else:
                   horizon_path = pr.path[: max(2, min(len(pr.path), self.cfg.horizon + 1))]
                   yield self._emit("plan", f"Plan up to date (on-line A*). Decide to subsequent {len(horizon_path)-1} strikes, then re-evaluate.", {"cause": pr.cause, "path_len": len(pr.path), "expanded": pr.expanded, "commit_horizon": self.cfg.horizon, "horizon_path": horizon_path, "grid_with_path": self.world.render(path=horizon_path)})
           if self.current_actions:
               planned_action = self.current_actions[0]
           else:
               ax, ay = self.world.agent
               tx, ty = self.world.goal
               choices = []
               if tx > ax: choices.append("R")
               if tx < ax: choices.append("L")
               if ty > ay: choices.append("D")
               if ty < ay: choices.append("U")
               choices += ["S","U","D","L","R"]
               planned_action = choices[0]
           motion, why = self._choose_action(planned_action)
           yield self._emit("determine", f"Intermediate resolution: motion={motion} ({why}).", {"planned_action": planned_action, "chosen_action": motion, "agent": self.world.agent, "goal": self.world.goal})
           time.sleep(self.cfg.act_latency)
           obs = self.world.step(motion)
           self.last_snapshot = obs
           if self.current_actions:
               if motion == planned_action:
                   self.current_actions = self.current_actions[1:]
                   if len(self.current_plan) > 1:
                       self.current_plan = self.current_plan[1:]
           ch = obs["changes"]
           shock = []
           if ch.get("target_moved"): shock.append("target_moved")
           if ch.get("obstacles_added"): shock.append(f"obstacles_added={len(ch['obstacles_added'])}")
           if ch.get("obstacles_cleared"): shock.append(f"obstacles_cleared={len(ch['obstacles_cleared'])}")
           surprise_msg = ("Surprises: " + ", ".be part of(shock)) if shock else "No main surprises."
           self.stats["steps"] += 1
           if obs["moved"]: self.stats["moves"] += 1
           if ch.get("target_moved"): self.stats["target_moves"] += 1
           if ch.get("obstacles_added") or ch.get("obstacles_cleared"): self.stats["world_shifts"] += 1
           yield self._emit("observe", f"Noticed consequence. {surprise_msg}", {"moved": obs["moved"], "agent": obs["agent"], "goal": obs["target"], "executed": obs["done"], "adjustments": ch, "grid": self.world.render(path=self.current_plan[: min(len(self.current_plan), 10)])})
           if obs["done"]:
               yield self._emit("executed", "Aim reached. Stopping execution.", {"final_agent": obs["agent"], "final_target": obs["target"], "stats": dict(self.stats)})
               return
       yield self._emit("executed", "Max steps reached with out reaching the purpose.", {"final_agent": self.world.agent, "final_target": self.world.goal, "stats": dict(self.stats)})